MotionLab
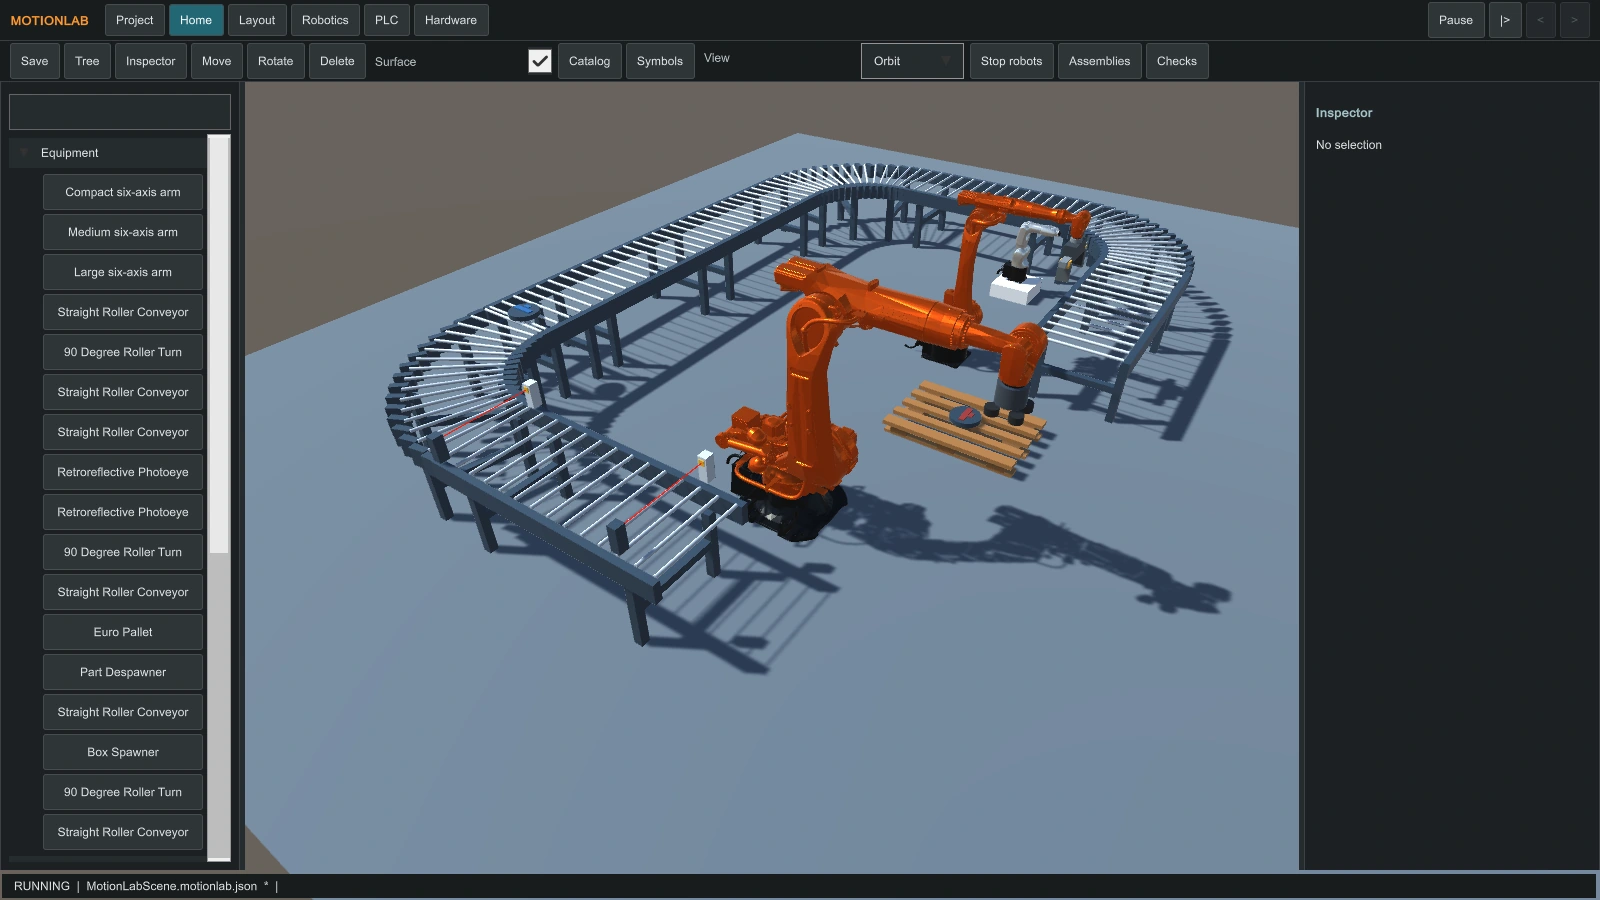
Build the cell.
Program the robot.
An industrial simulation workspace for assembling robot cells, teaching motion, and testing how robot programs, PLC logic, and factory devices interact.
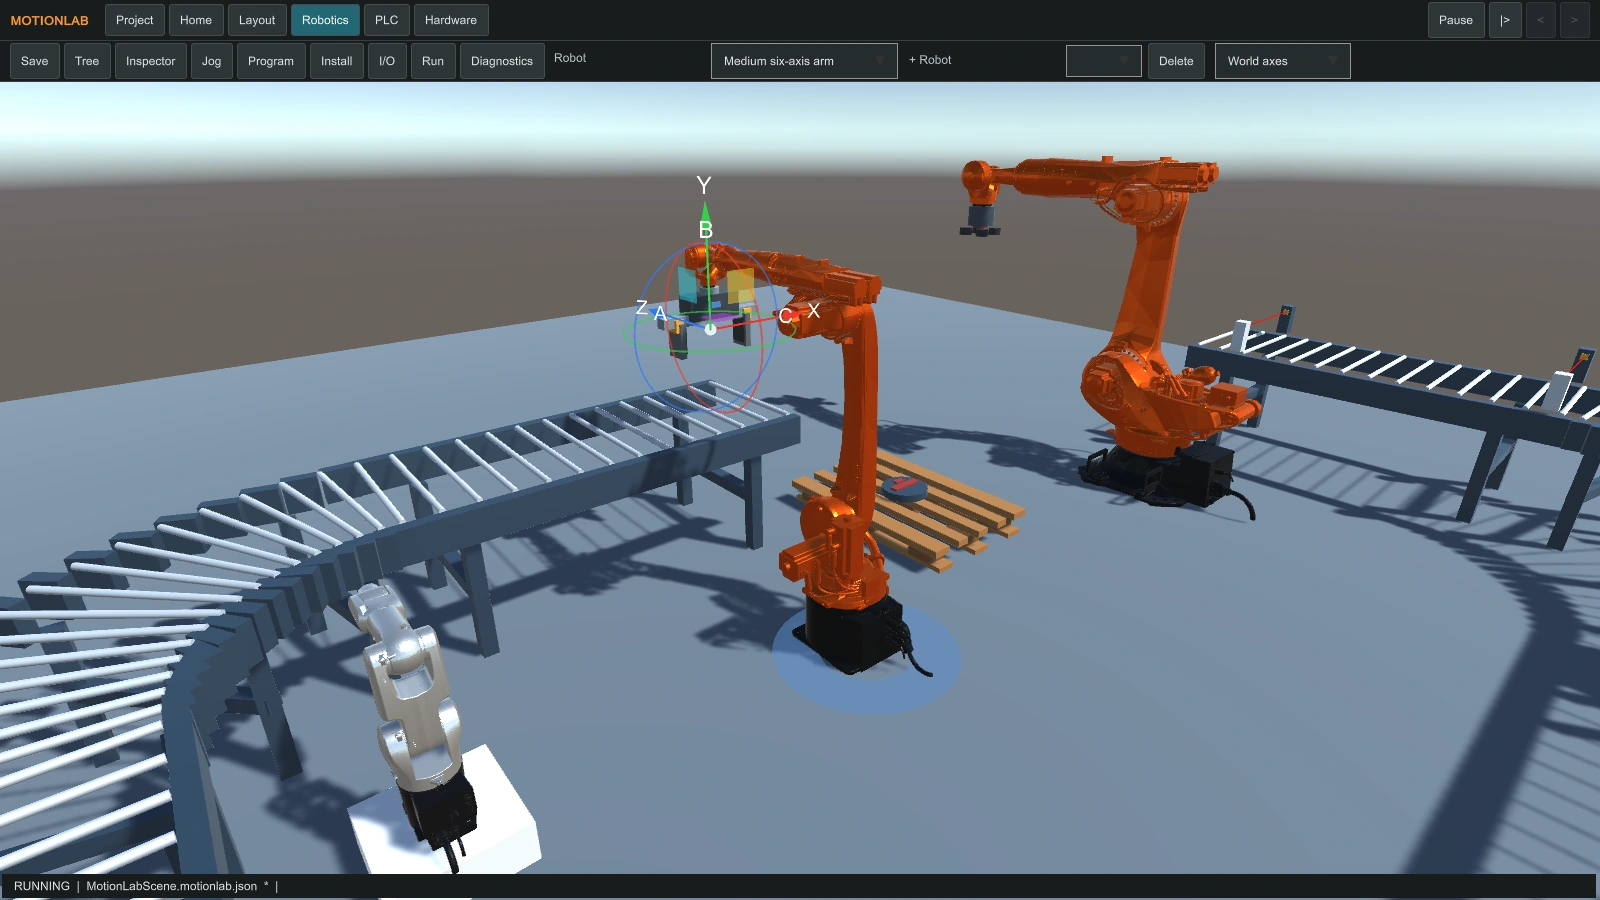
Position the tool in the viewport
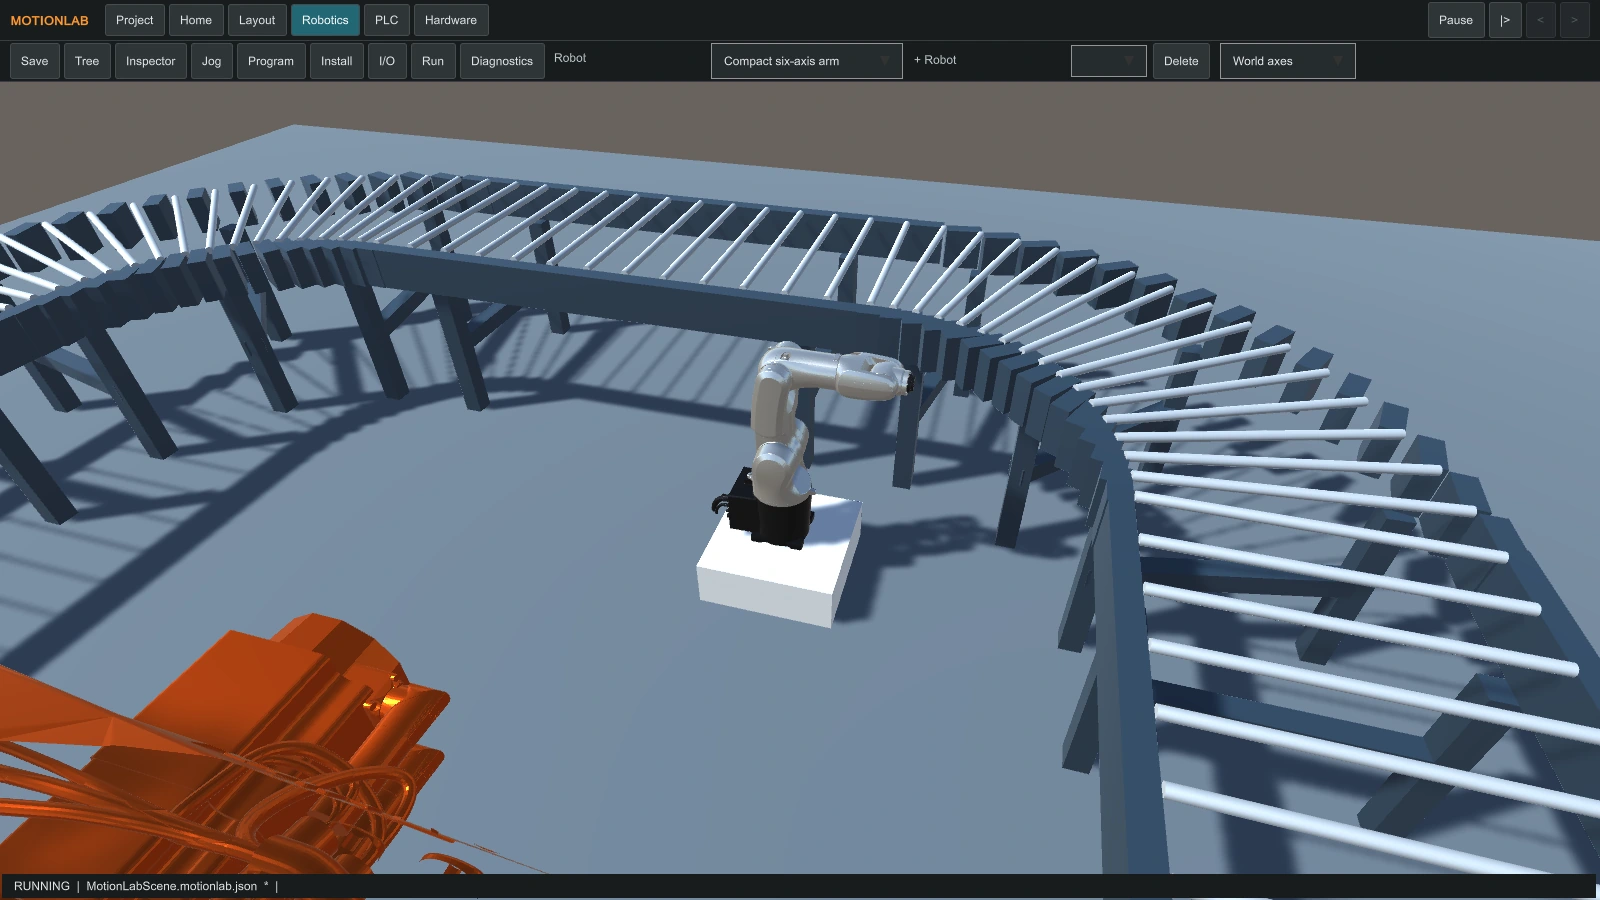
MotionLab can work with several robot models in the same cell. Use the six-axis TCP gizmo to move or rotate the selected tool in world or tool coordinates. The preview shows the target pose before a move is committed.
Program on a working teach pendant
Jog joints or the tool center point (TCP), define tool and user frames, teach waypoints, and write retained programs. Use HOME and point-to-point instructions for joint moves, SLIN for straight paths, and SCIRC for arcs. Step through instructions, set breakpoints, or run a cycle in the simulated AUTO mode.
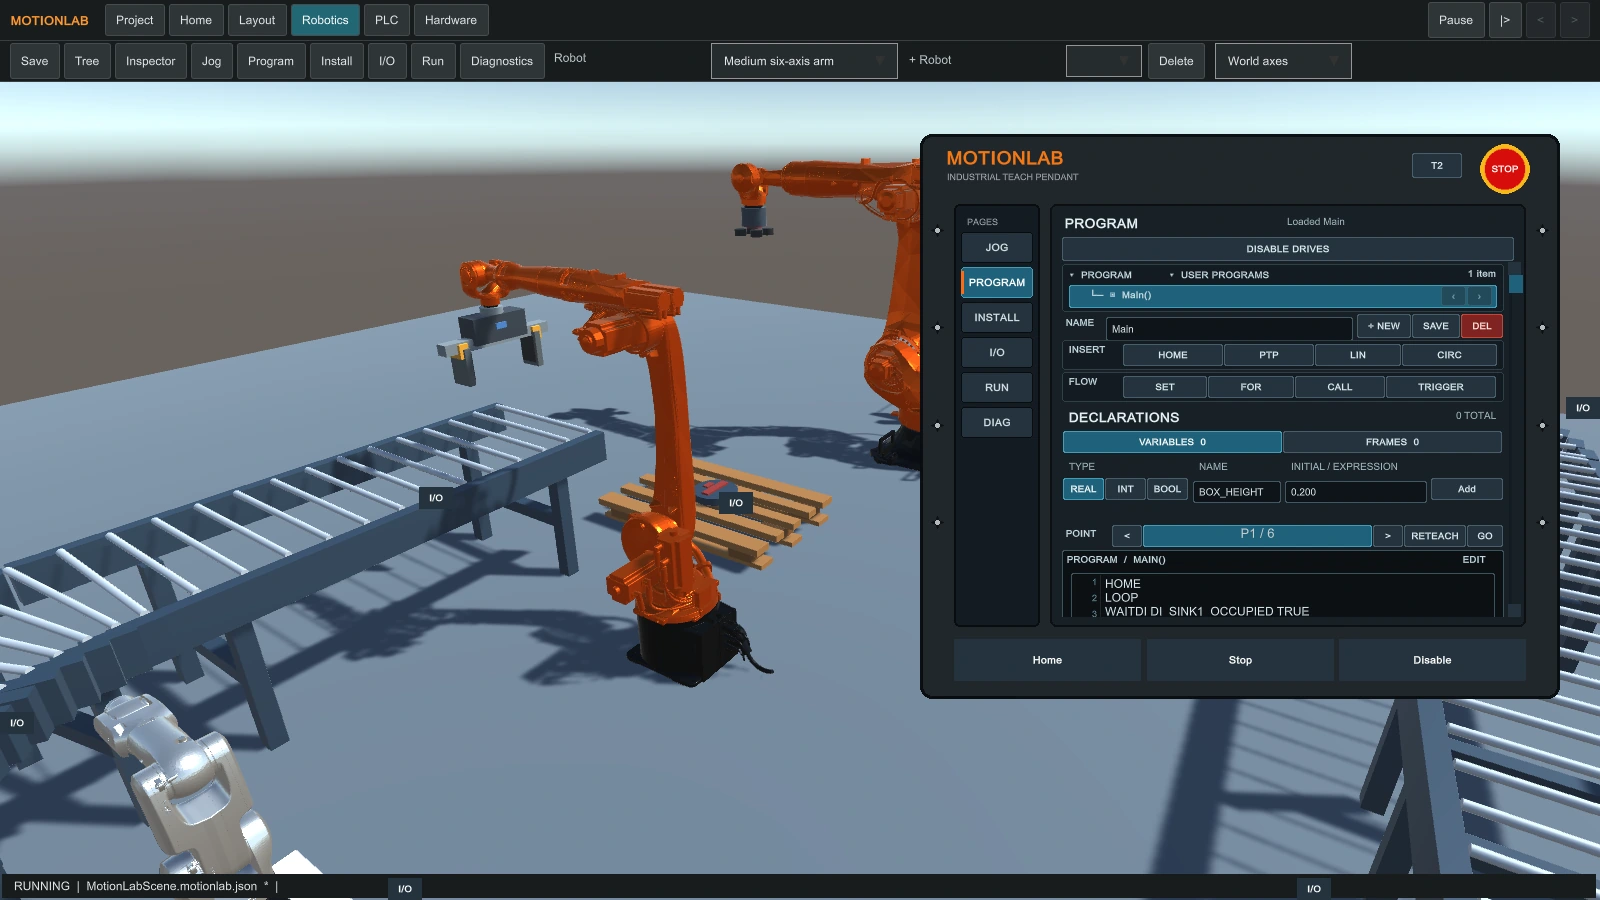
Pick sequence from the demo cell
WAITDI DI_SINK1_OCCUPIED TRUE
SPTP P1 VEL=1 ACC=1 JERK=10 APO=0
SLIN P2 VEL=0.2 ACC=1 JERK=10 APO=0 ORI=VAR
SETDO GripperClose True
WAITTIME 0.5
Connect robot actions to the cell
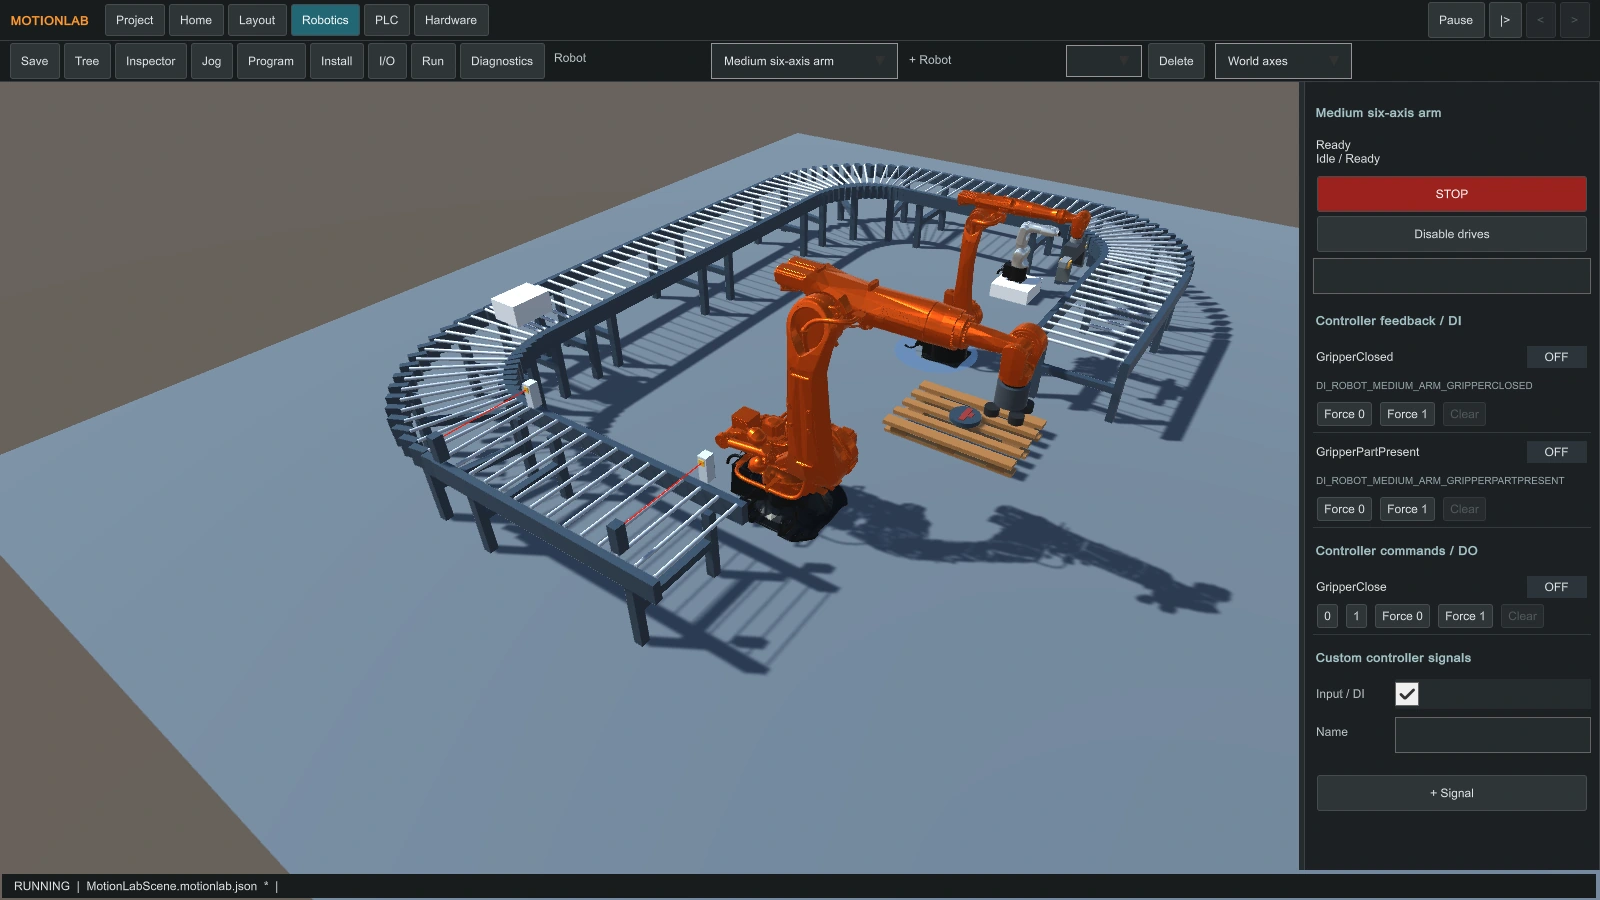
Robot programs and factory devices share symbolic digital I/O. A program can wait for a photoeye, switch a gripper or vacuum output, and read feedback before moving on. Device faceplates expose live state for conveyors, sensors, sources, and sinks.
Write and observe PLC logic
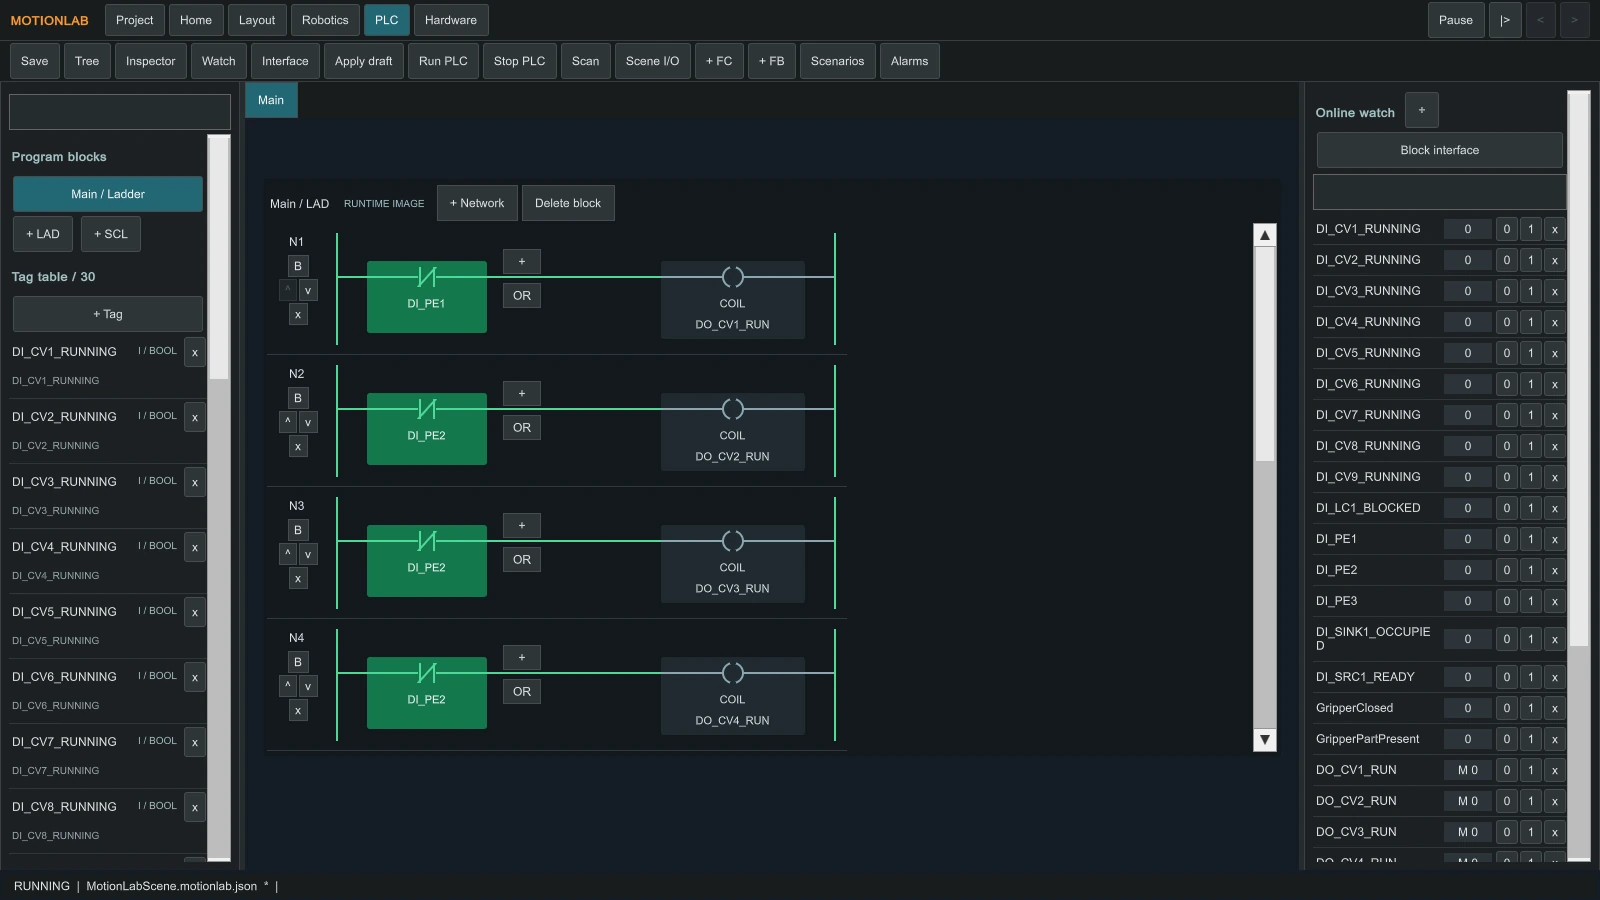
Build visual ladder (LAD) rungs or write SCL blocks. Map typed tags to the simulated sensor and actuator bus and use timers, counters, and online watch. Run, stop, or single-step the scan to see how a change to an input affects the cell.
From cell layout to hardware tests
MotionLab brings layout, robotics, PLC, and controller sessions into one project. The hardware work is still in development.
Build a cell
Import URDF robots and assemble resizable conveyor sections, pallets, sensors, and fencing with compatible snap points. Save the cell with its installed tools and programs.
Supported controller work
The hardware workspace supports loopback testing and an SO-101 bridge for physical feedback and joint control. The real-arm bridge still needs calibration and supervised bench validation.